WildFab: Multi-Axis 3D Printing from Models in the Wild
ACM TOG · SIGGRAPH Asia 2026 (to be presented)
Building computational innovation to drive the physical intelligence of manufacturing and robotics systems.
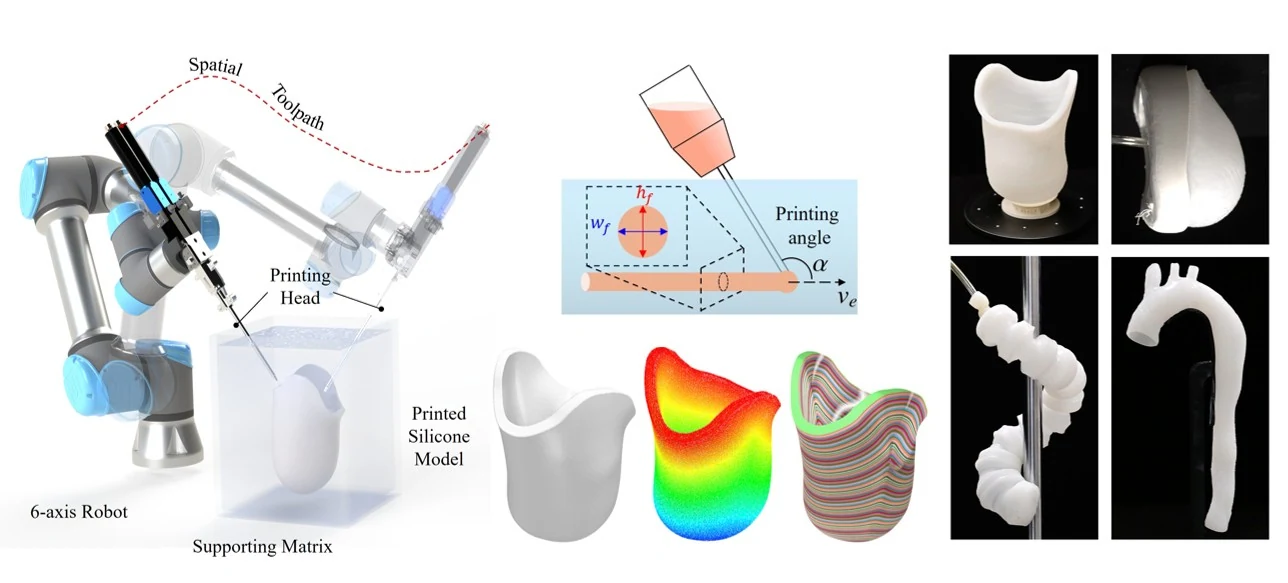
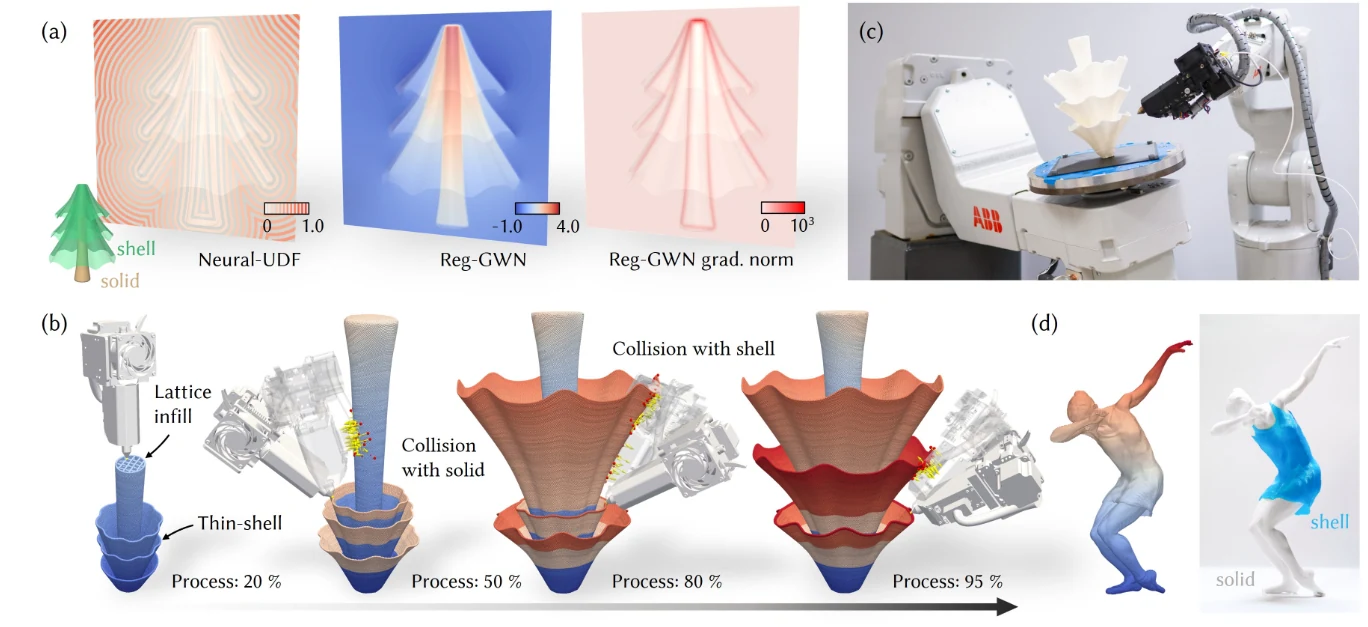
Multi-axis additive manufacturing (MAAM) has garnered significant attention for addressing the limitations of traditional planar-based 3D printing solutions, which rely on fixed nozzle orientations. By dynamically adjusting the printing direction using high degrees-of-freedom setups - e.g., robot arm, MAAM enables advanced capabilities such as support-free printing, improved surface quality, and precise control over anisotropic material properties. Our research in MAAM focuses on the key areas:
ACM TOG · SIGGRAPH Asia 2026 (to be presented)
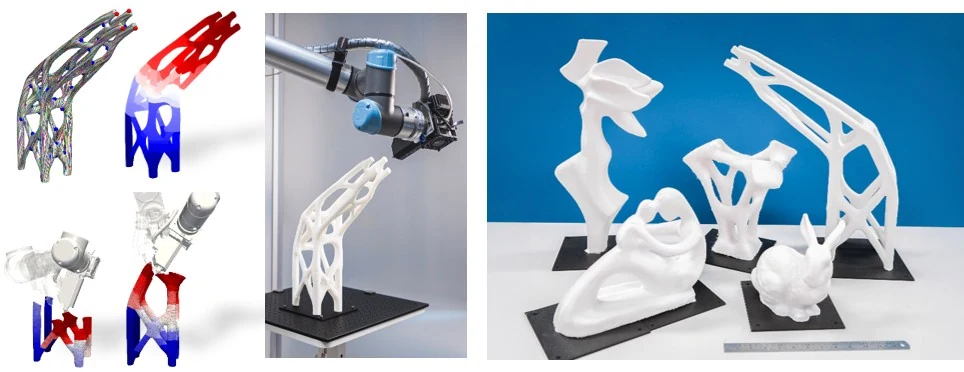
ACM TOG · SIGGRAPH Asia 2025
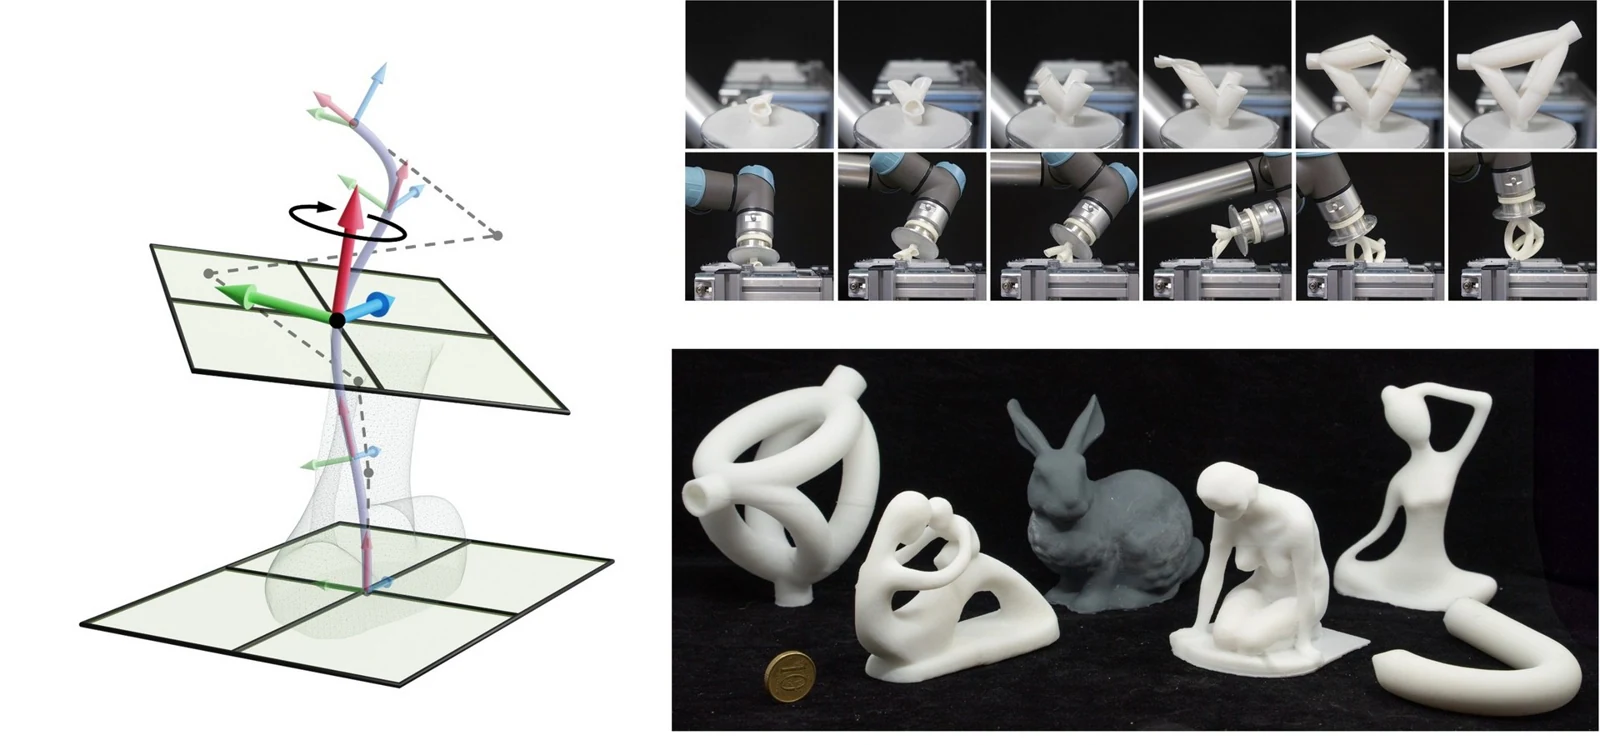
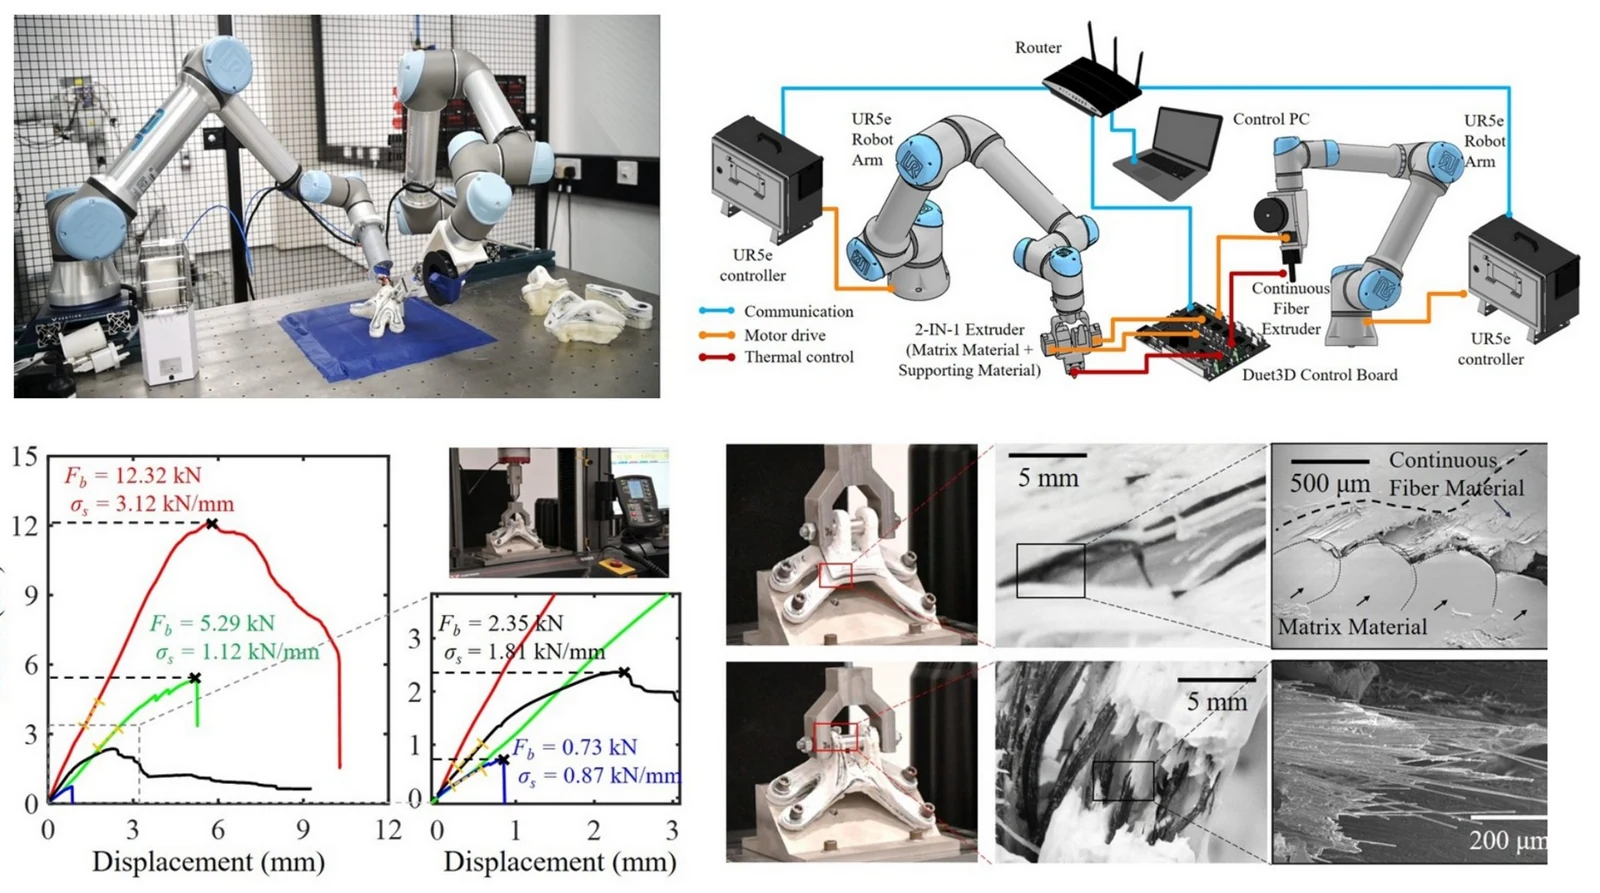
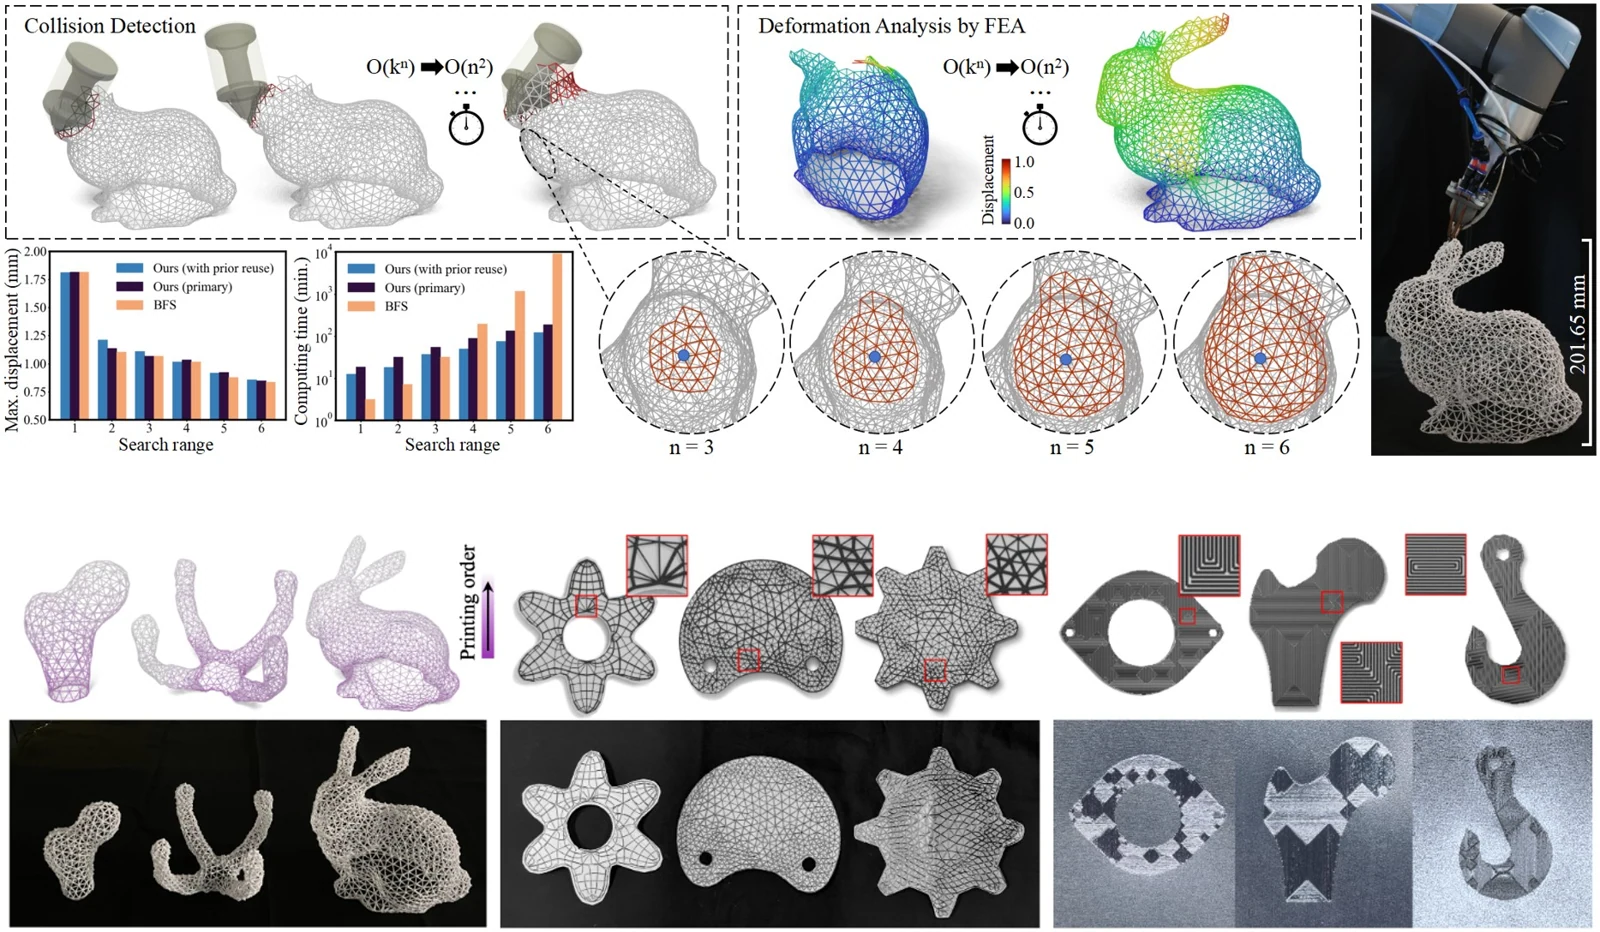
ACM TOG · SIGGRAPH Asia 2024
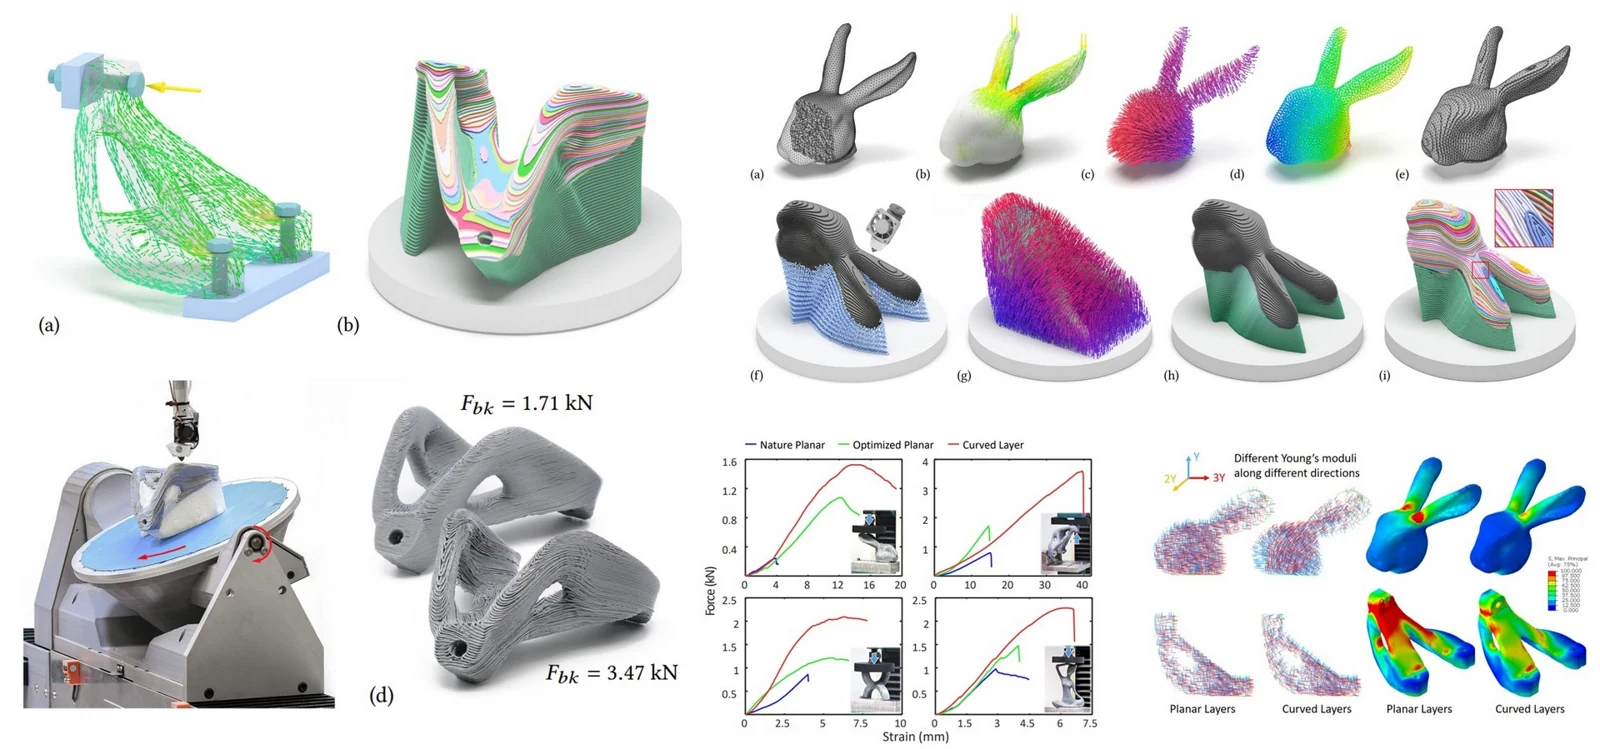
ACM TOG · SIGGRAPH Asia 2020
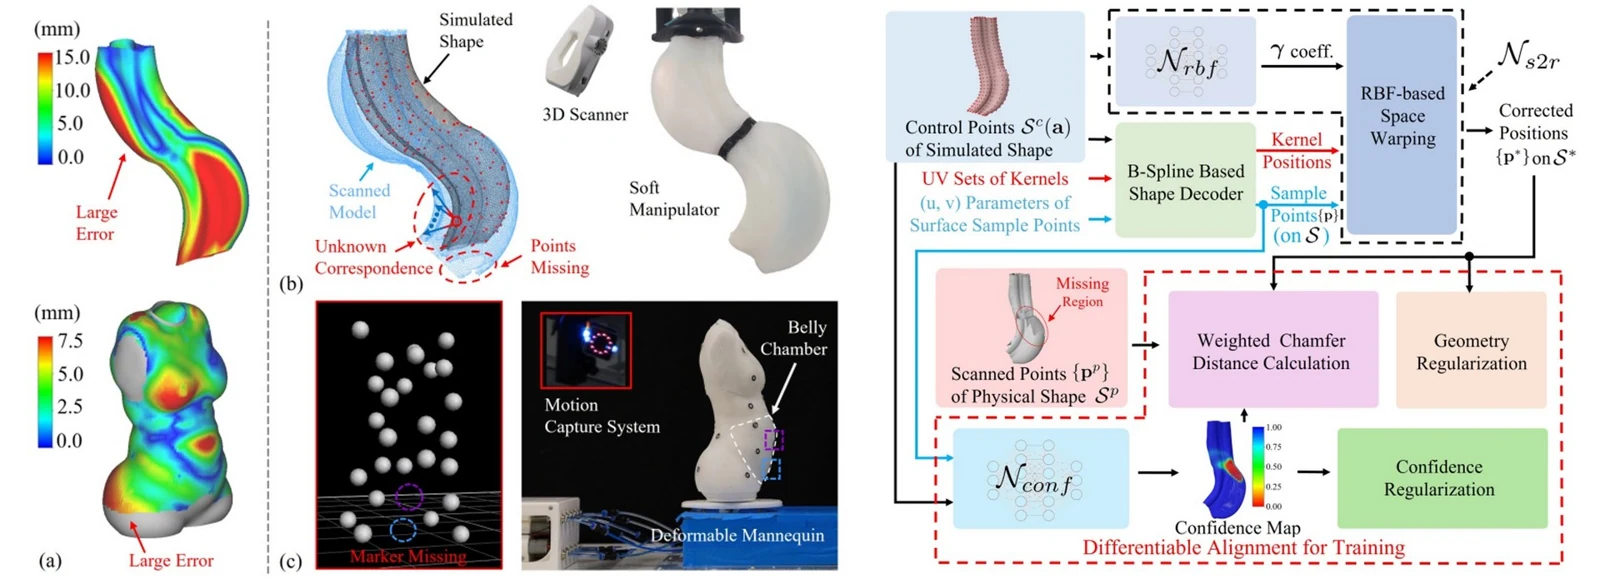
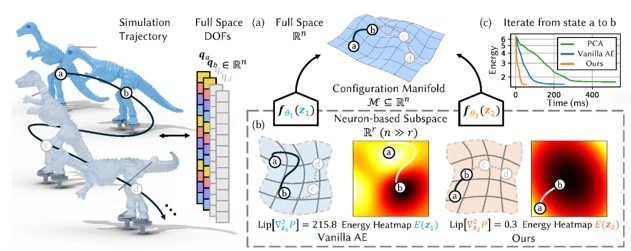
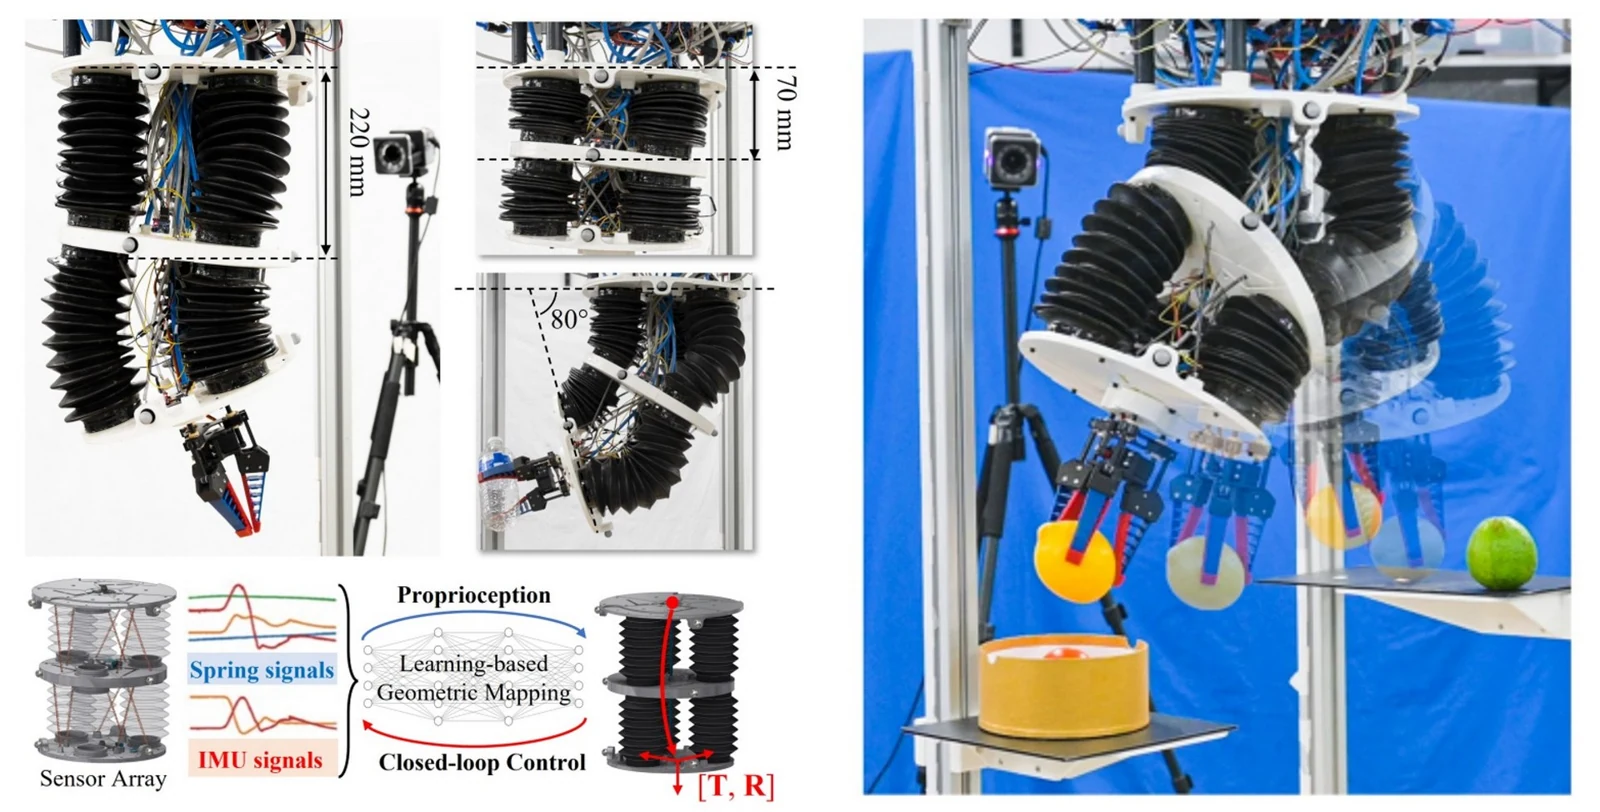
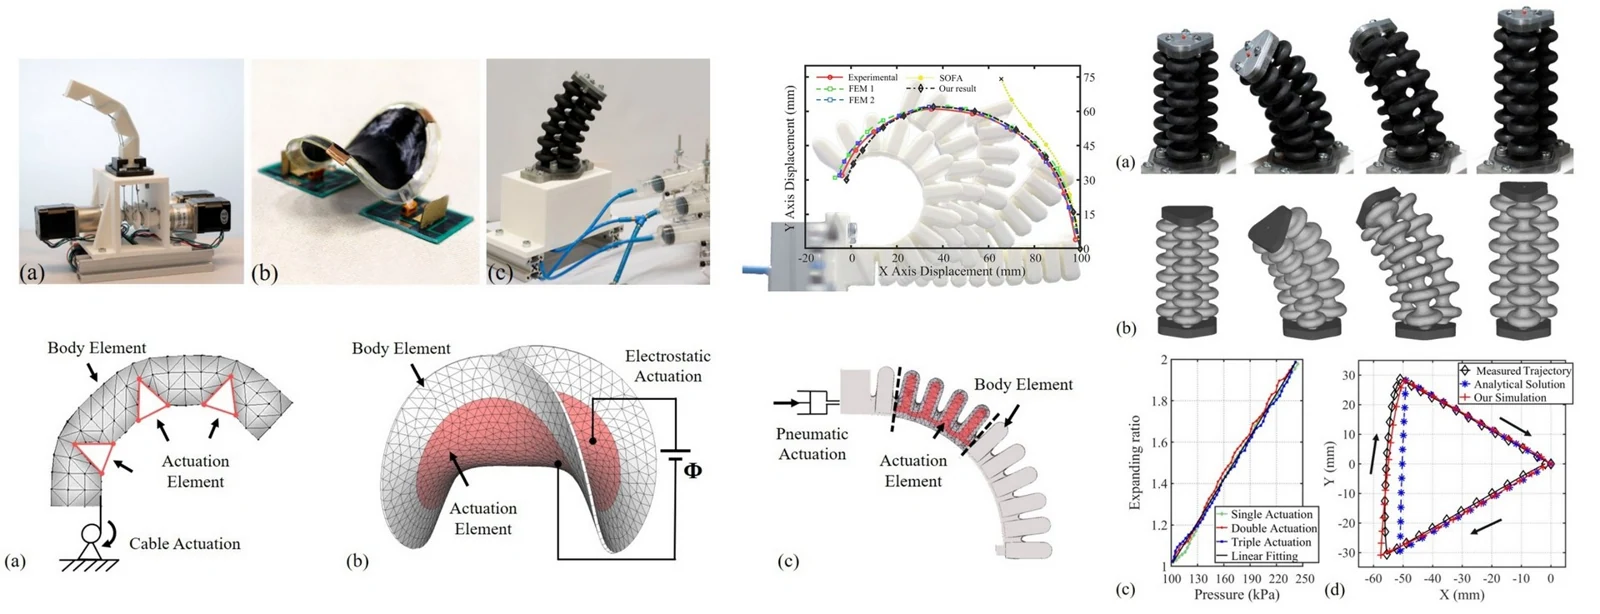
We develop computational methods for the digital fabrication and control of compliant robotic systems. Our work combines geometric modeling and learning to understand deformation and guide motion. We connect fabrication with sensor design and proprioception to bring simulation-based control into physical robots.
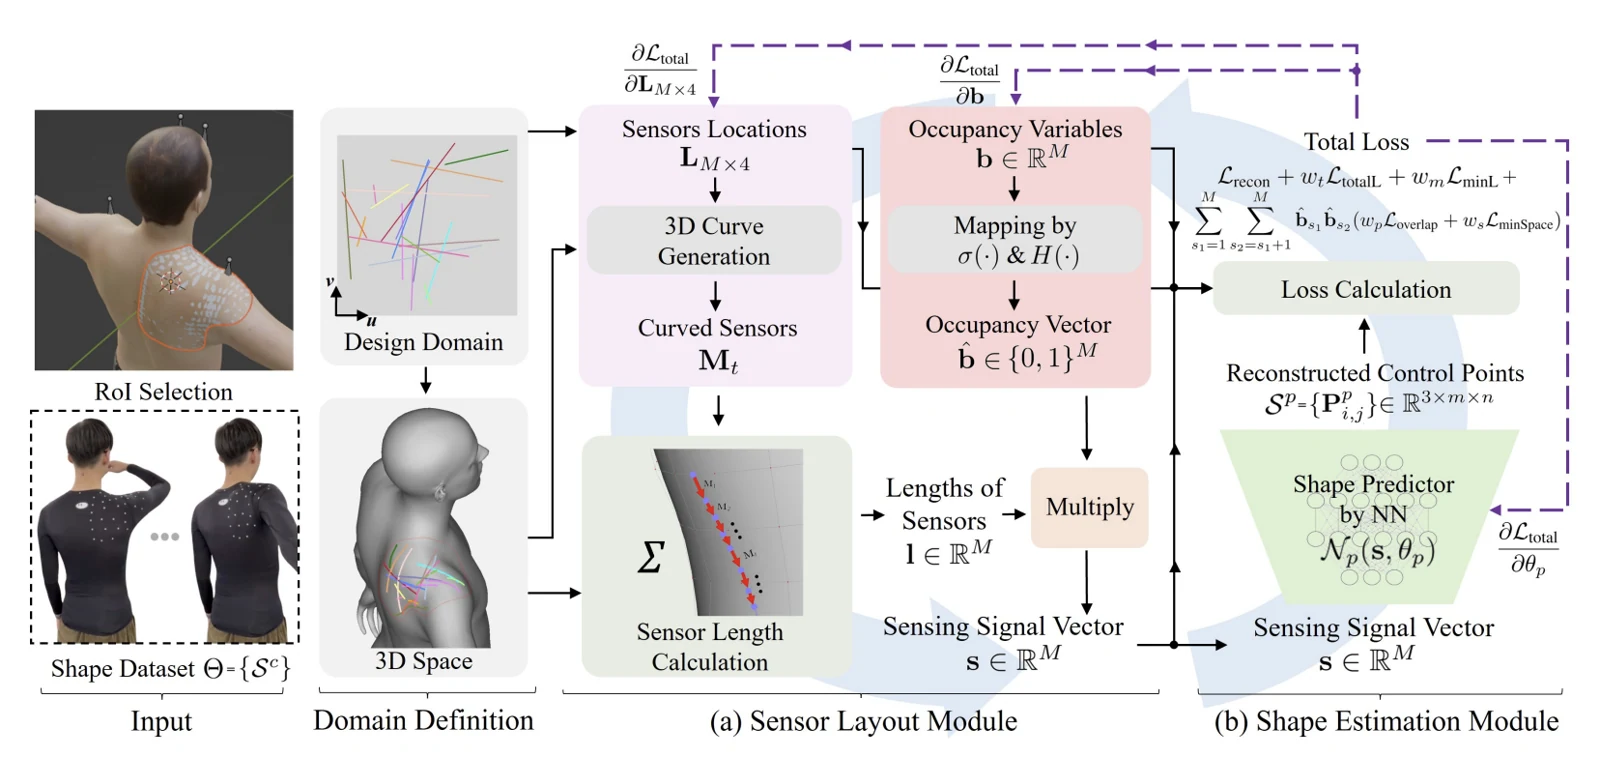
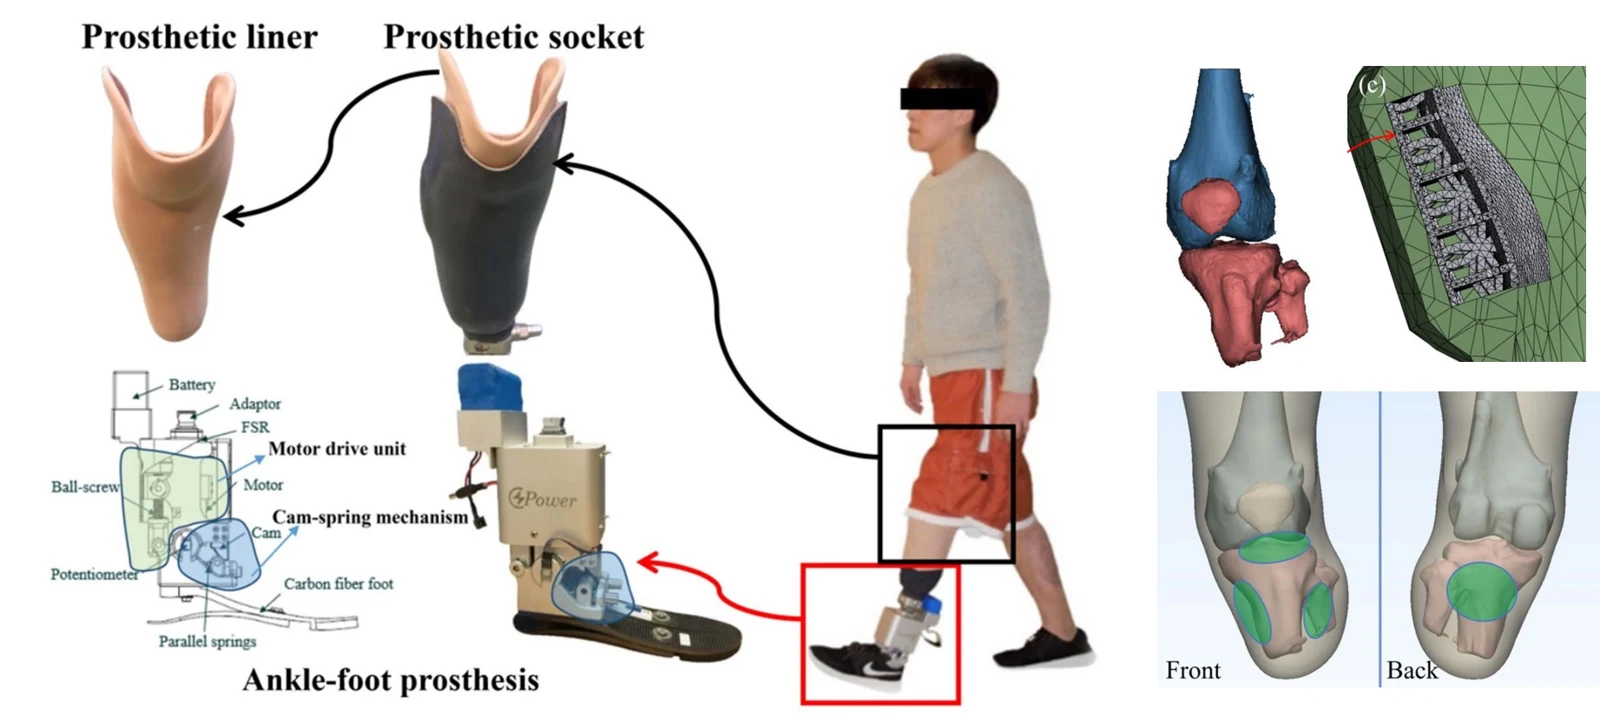
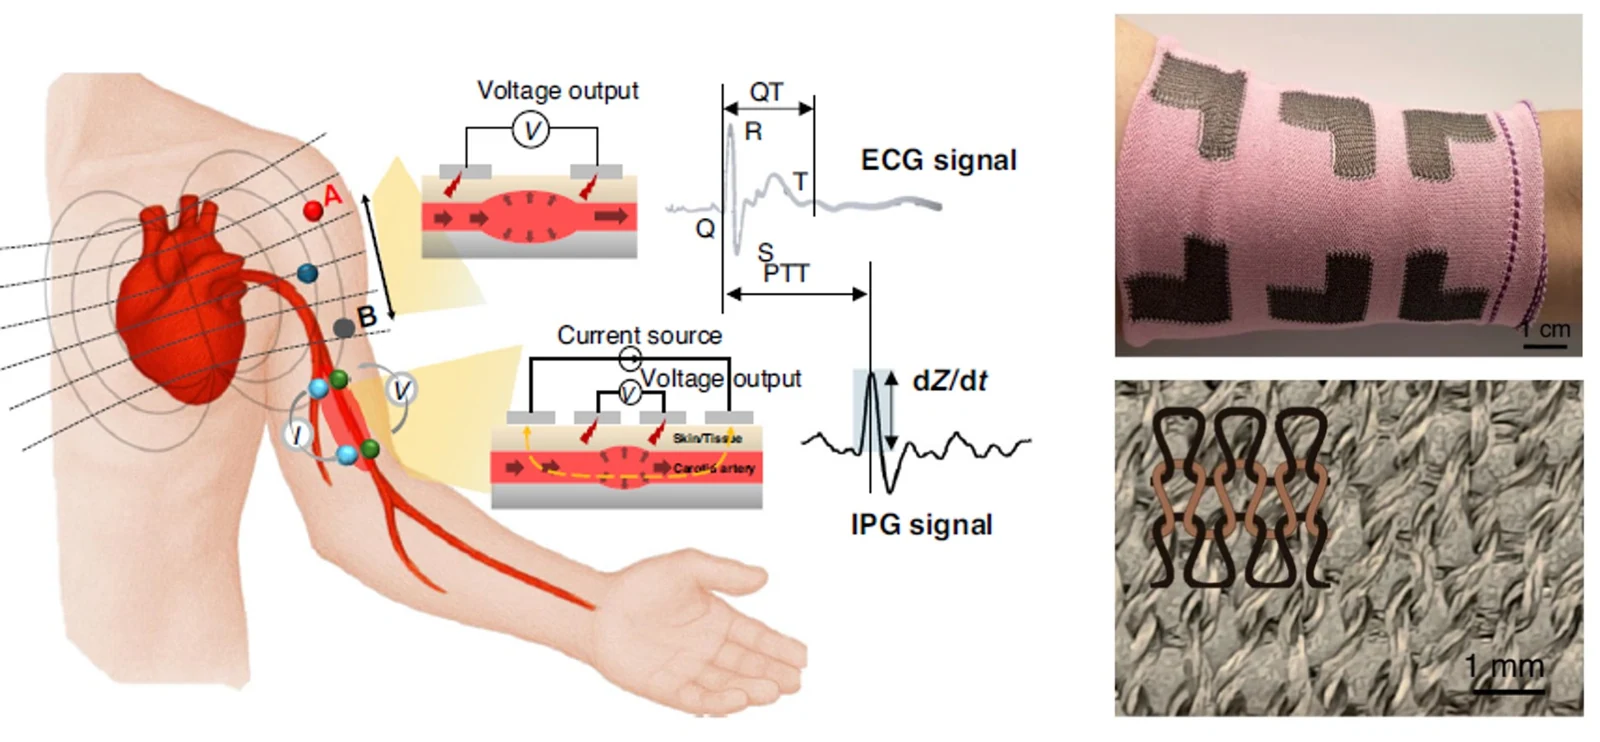
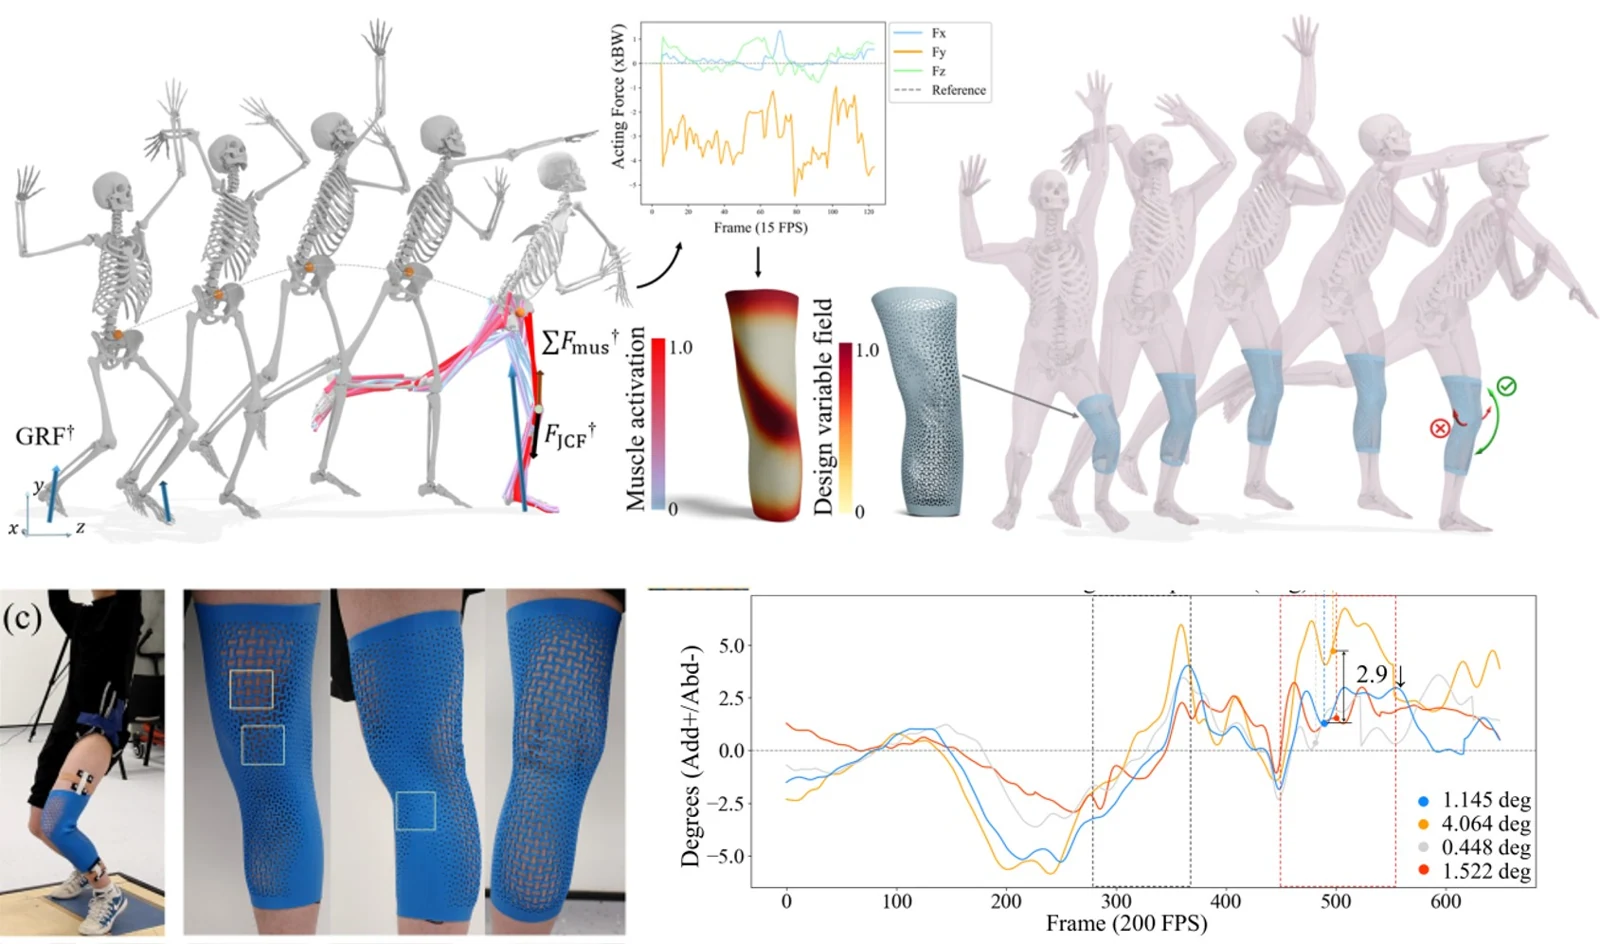
Personalized, high-performance systems tailored to individual anatomy and function have become increasingly feasible. By leveraging advanced modeling tools and data-driven design workflows, we enable the precise adaptation of devices—such as prostheses, exoskeletons, and health-monitoring wearables—to users’ unique physiological and ergonomic needs. Our research on wearable devices focuses on computational design and digital fabrication to enable customized, functional solutions. Through the seamless integration of computational intelligence and fabrication technologies, our approach advances the next generation of functional, comfortable, and accessible wearable systems that enhance quality of life and human–robot interaction.